Tim
2014Built for AERIAL ASSIST, the 2014 FIRST Robotics Competition game.
- Status
- —
- Weight
- —
- Drivetrain
- —
- Signature mechanism
- —
- Size
- —
- Season record
- —
Performance: Regular season
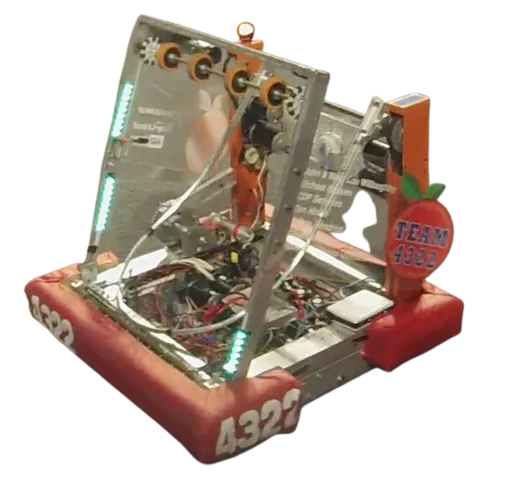
The 2014 season, start to finish
Events and results from The Blue Alliance · EPA from Statbotics · build-season activity from Chief Delphi and GitHub- JanuaryKickoffSeason startAERIAL ASSIST revealed
- Jan–FebBuild seasonSix weeks
- Feb 28Inland Empire RegionalWeek 1Regional EventGrand Terrace, CA
- Apr 3Las Vegas RegionalWeek 6Regional EventLas Vegas, NV
AERIAL ASSIST

AERIAL ASSIST is played by two competing Alliances of three Robots each on a flat 25’ x 54’ foot field, straddled by a lighting truss suspended just over five feet above the floor. The objective is to score as many balls in goals as possible during a 2 minute and 30 second match. The more Alliances score their ball in their goals, and the more they work together to do it, the more points their alliance receives.
The match begins with one 10-second Autonomous Period in which robots operate independently of driver. Each robot may begin with a ball and attempt to score it in a goal. Alliances earn bonus points for scoring balls in this mode and for any of their robots that move in to their zones. Additionally, each high/low pair of goals will be designated “hot” for five seconds, but the order of which side is first is randomized. For each ball scored in a “hot” goal, the Alliance earns additional bonus points.
For the rest of the match, drivers remotely control robots from behind a protective wall. Once all balls in autonomous are scored, only one ball is re-entered in to play, and the Alliances must cycle a single ball as many times as possible for the remainder of the match. With the single ball, they try to maximize their points earned by throwing balls over the truss, catching balls launched over the truss, and scoring in the high and low goals on the far side of the field.
Alliances receive large bonuses for “assists,” which are earned for each robot that has possession of the ball in a zone as the ball moves down the field.
How we played it
Features are added from the robot's settings.
Events and results
Inland Empire Regional
Week 1Regional EventGrand Terrace, CA · Feb 28, 2014- Rank
- —
- Record
- —
- Playoffs
- —
- EPA at event
- —
Las Vegas Regional
Week 6Regional EventLas Vegas, NV · Apr 3, 2014- Rank
- —
- Record
- —
- Playoffs
- —
- EPA at event
- —
Code
Repositories linked to this robot, read from GitHub: description, language, activity through the season, and the latest commit. Private repositories show as a plain link.
No repositories linked yet.
Refreshed a few times a day from the GitHub API and cached, so the page never waits on GitHub.2014 build thread
This robot has no Open Alliance build thread on Chief Delphi.
Gallery
Photos appear here once a mentor approves them.